Gripper Selection for Mixed-Material Grasping
Five gripper types match different materials; picking one for all will fail.
Gripper selection for mixed-material grasping comes down to matching one of five gripper technologies to four measurable variables: surface texture, rigidity, weight, and fragility. Skip that matching exercise and the usual result is a gripper that handles most objects on a line beautifully and fails on the rest. Here's the position the rest of this piece is built to defend: no single gripper works best across a genuinely mixed line, and shopping for one anyway is the single most common way these projects fail.
A lot of procurement meetings run on the instinct to find the one gripper that does everything. Buy the capable one, the thinking goes, and every object on the line becomes someone else's problem. That instinct runs into trouble because "mixed-material" rarely means just different shapes. It means different surface textures, different porosity, different stiffness, different weight, and different fragility thresholds, often all present in the same bin on the same shift. A warehouse pulling SKUs for e-commerce fulfillment might handle a rigid blister pack, a soft polybag, and a crushable cardboard box in three consecutive picks, with no warning of which is coming next. Single-stream recycling sorting has the same problem in a dirtier form: glass, aluminum, wet cardboard, shredded film plastic, sometimes touching each other in the same scoop. Food processing and medical device assembly hit the same wall, just with higher stakes attached to getting it wrong.
Industrial automation grew up in sectors that never had this problem to begin with. Electronics assembly and automotive manufacturing standardized their physical forms decades ago, which is exactly why a single rigid parallel-jaw setup could run a shift without incident: every part on the line had the same geometry as the last one. Current gripping solutions still fall short once object variability climbs past what those standardized lines were built for. Grasping across genuinely different physical states, solids next to liquids next to semi-solids, remains one of the open problems in soft robotics; nobody has shipped a gripper that spans that whole range, likely because that gripper isn't a physically coherent design in the first place.
Even without saying so out loud, the market has noticed. The global robot grippers market sat at an estimated USD 1,465 million in 2024 and is forecast to reach USD 4,690 million by 2031, a compound annual growth rate of 18.4%. That climb tracks demand for flexible handling systems specifically, a fairly direct signal that the industry is actively seeking more adaptable approaches.
The five gripper types and what each actually does well
These five function as a capability map, not a leaderboard. Each is suited to a specific domain and poorly suited everywhere else. Anyone still hunting for the one gripper to handle every material should notice that no such design exists yet, and probably won't for a while.
Rigid, parallel-jaw grippers are the industry workhorse: metal construction, pneumatic or electric actuation, a binary open-close motion. Strong grasping force, fast response, tight control, none of that is in question. They have no passive adaptation to an unexpected shape; the jaws close to the geometry they were built for, and anything outside that geometry either slips or gets crushed. Good for heavy standardized parts moving down a structured line. Bad the moment the line stops being structured.
Soft grippers, whether pneumatic, tendon-driven, or built from shape memory alloy wire, sit at the opposite end. They deform on contact and conform to whatever shape shows up, without needing a camera or a sensor to tell them what that shape is. That makes them safe around fragile objects and safe around people, which matters more than it sounds given how many warehouses now run humans and robots on the same floor. The field generally splits soft designs into three buckets: actuation-based, stiffness-modulation-based, and adhesion-control-based. The tradeoff is what you'd expect from something built to bend: weaker grasping force, slower response, less precise control than a rigid jaw ever has to worry about.
Hybrid soft-rigid grippers pair rigid structural elements with compliant segments so the gripper gets some force along with some give. Modular versions get reconfigured for multiple tasks, cutting capital cost for a plant that doesn't want a separate gripper for every product line. One FDM 3D-printed hybrid rigid-flexible design held stable grasps across different shapes and surface materials while sustaining forces above 50 N under varied contact conditions, a meaningful number for anything heavier than light packaging.
Vacuum and suction grippers are the obvious choice for flat, large objects approached from above; a single cup making contact is usually enough, regardless of the object's exact dimensions. A standard Venturi ejector, running high vacuum, handles smooth non-porous surfaces about as well as anything can. The trouble shows up on porous or irregular material, where the seal just won't hold. Hybrid vacuum systems address this by switching in real time between high-vacuum Venturi mode and high-flow regenerative-blower mode, closing suction's biggest historical weakness.
Granular jamming grippers work through a different mechanism entirely. The granular fill flows around the object on contact, and applying vacuum hardens the whole mass into a grip, no sensory feedback required. Volume changes of less than 0.5% are enough to grip an object and hold it with a force many times its own weight. Granulate size and envelope material are both tunable; one 2024 materials-optimization study tested 16 prototype combinations across four granulate sizes and four envelope materials, using glass balls ranging from 0.2 to 1 mm to test the effect of grain size. Granulate material choice remains an active area of investigation, with different fill types offering different tradeoffs in adaptability and stability. Granular jamming's surface stays simple by design, though, which makes it awkward to bolt tactile sensors onto.
Electroadhesive and gecko-inspired grippers are the specialists on this list. Electroadhesive film varies its friction coefficient electrically, letting a single film handle a range of materials without swapping hardware, while cutting damage to whatever it's holding. Gecko-inspired designs, SCHUNK's ADHESO being one example, use Van der Waals forces to stick to a surface without suction and without clamping force. Both earn their keep on smooth, non-porous, delicate, or flat surfaces where vacuum would either fail outright or do damage on the way in.
How surface texture and porosity narrow the field immediately
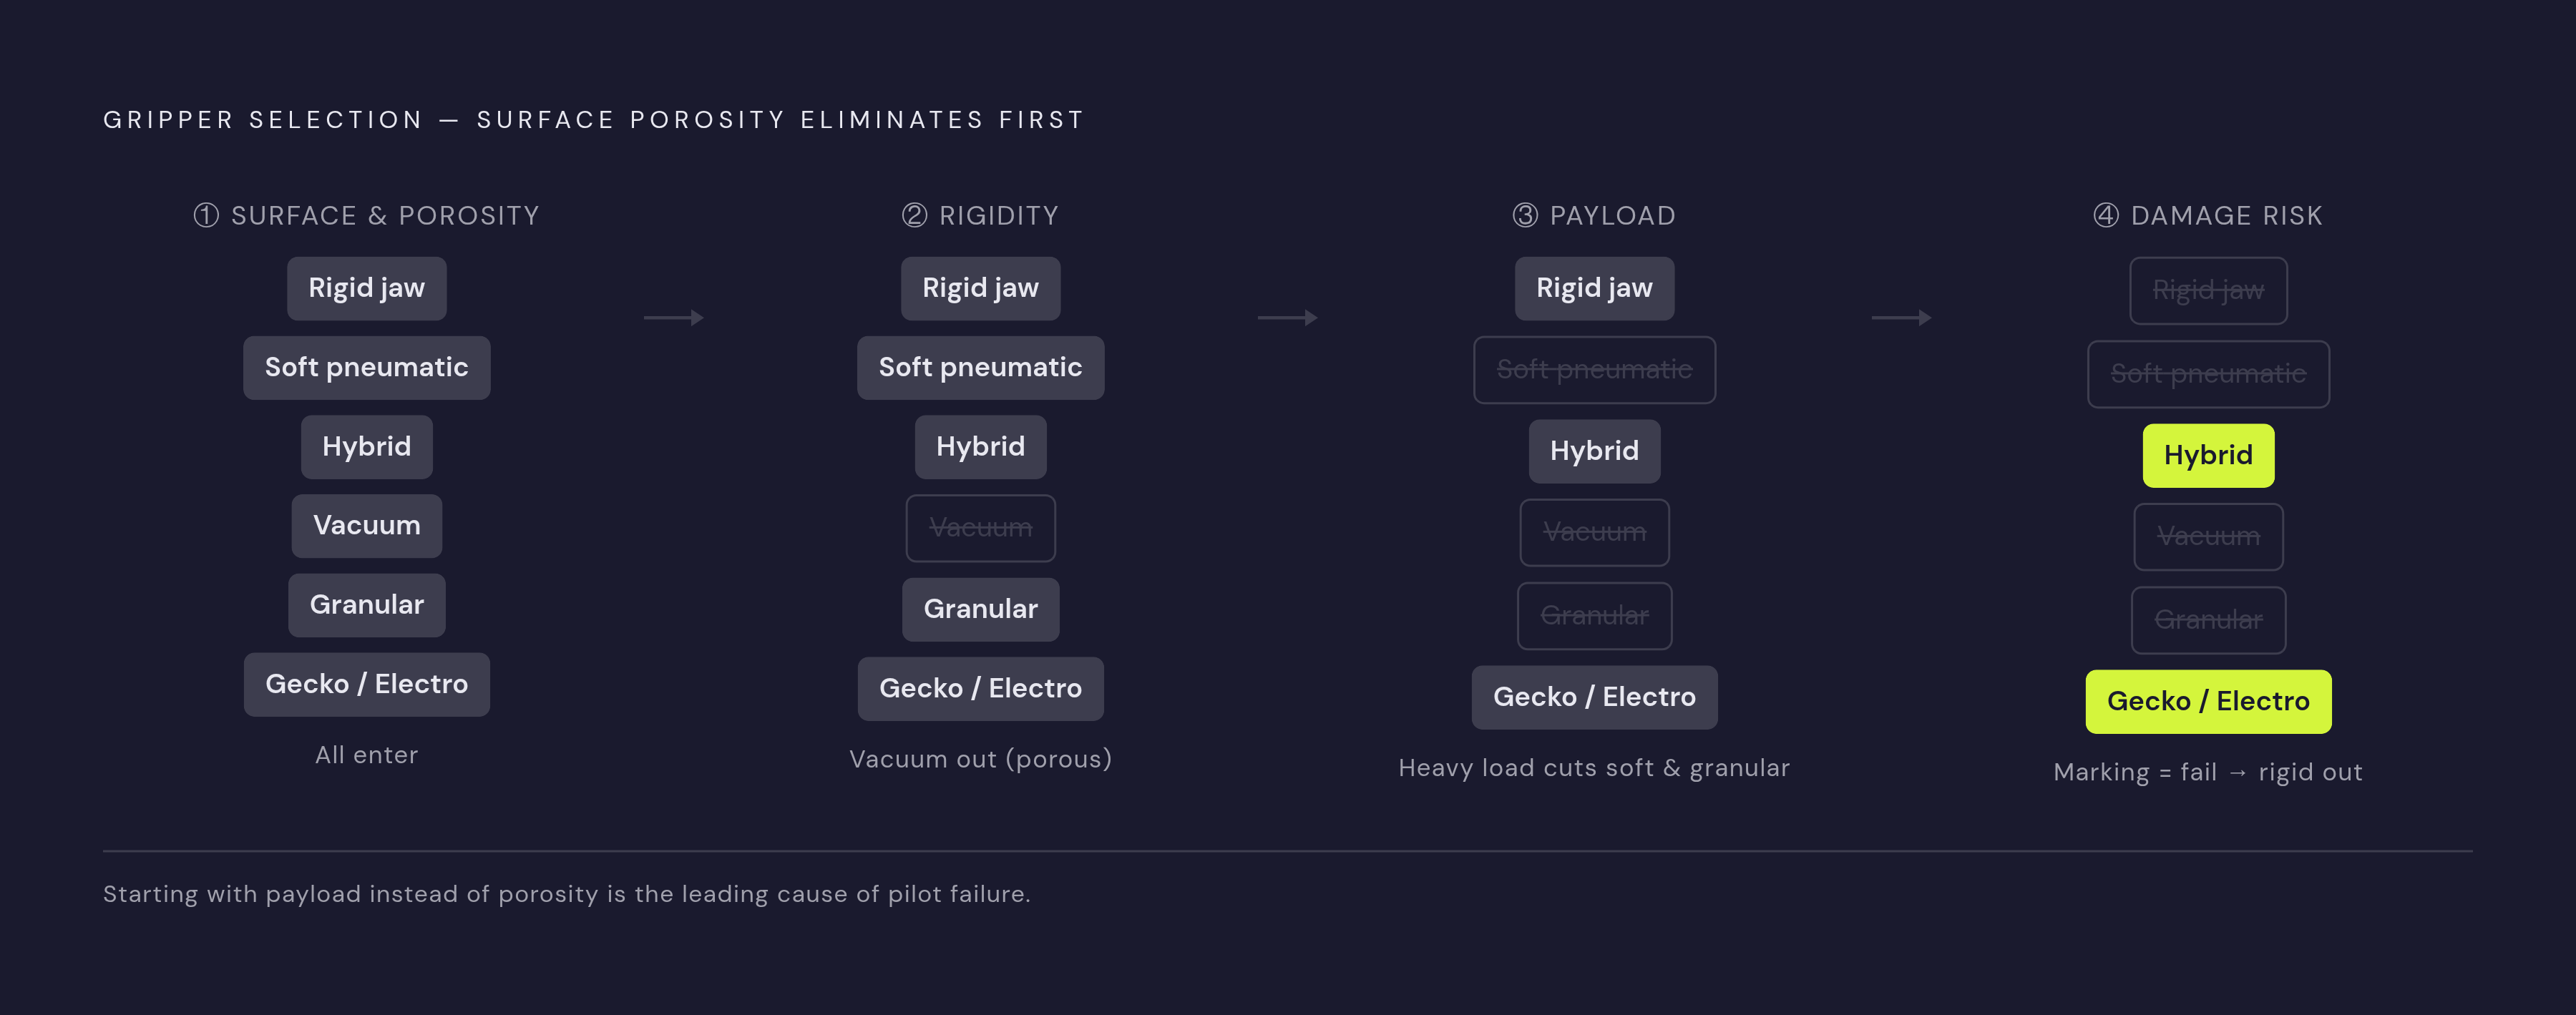
Porosity is the fastest way to eliminate a gripper family, and it happens before payload or fragility even enter the room. This is where most procurement conversations should start, and don't; they start with payload instead, which gets the order backwards, and it's a leading reason pilots stall three months in. Smooth, non-porous surfaces are where standard high-vacuum Venturi suction is close to optimal: fast, clean, high throughput, nothing fancy required. Porous or permeable materials, textiles, open-cell foam, most fabric, break that seal immediately. Suction alone won't hold, and the fix is either a hybrid vacuum system with a high-flow blower mode or an intrusive mechanism like a needle gripper, which uses micro-needles that penetrate the surface just slightly. Needle grippers cause less damage than clamping would, which is the whole reason they exist for fabric handling in the first place.
Surface curvature is the second filter, and it works independently of porosity. A highly irregular or curved shape defeats a flat suction cup no matter how non-porous the material is; granular jamming or pneumatic soft fingers conform passively where a flat cup just can't make contact. Mixed lots, some items flat, some irregular, riding the same line, are exactly the scenario a hybrid vacuum gripper's real-time mode switching was built to solve, and it's usually the practical answer wherever throughput matters more than swapping end-effectors between picks.
Surface material adds a third axis worth naming: metallic versus non-metallic. Surface material detection systems let a multifunctional gripper identify a metallic object and switch on auxiliary electromagnetic grasping without swapping any hardware. In a mixed lot with both ferrous parts and non-metallic items, a detection-plus-electromagnetic strategy handles the metal subset without forcing a gripper swap for the rest of the line.
Put those three together and the sequencing gets clear fast: surface properties alone tend to knock out one or two gripper families before rigidity or weight ever gets a vote. Gripper selection is a filter, applied in order. Skip straight to payload before surface has been ruled on, and the team ends up back at square one, wondering why the "capable" gripper keeps dropping every fourth item.
Where rigidity and payload requirements take over the decision
Once the surface filter has done its work, stiffness takes over. Mixed-material environments can span a range running from liquids through metals, and no single gripper covers that whole span, not even the hybrids. Soft grippers own the low end: passive deformation lets them hold a stable grasp across varying shapes and give, without needing to know in advance exactly how soft the object is. Rigid grippers own the opposite end, where strong force and tight control make them the reliable pick for metal parts and hard plastic. Hybrid designs are the practical middle ground for any workflow that sees both categories on a regular basis, which describes most mixed-material lines whether the plant manager admits it or not.
Worth flagging here is a bonus: a parallel jaw gripper fitted with force and torque sensors can gather contact-force data that helps characterize the object being held. That doubles as a crude form of object recognition, useful in contexts where object identification during the grasp itself adds value.
Payload is the other half of this filter, and it's where soft grippers hit a wall. Weak grasping force relative to rigid designs is the tradeoff soft grippers accept in exchange for conformability, and payload is the variable most likely to disqualify them outright once the object gets heavy. Hybrid rigid-flexible designs close a good chunk of that gap, again, that 50 N figure from the FDM-printed prototype under experimental testing. For genuinely heavy industrial loads, though, a rigid or rigid-dominant hybrid gripper is the sound choice on the table, regardless of how irregular the surface underneath it happens to be.
Stack stiffness and payload together and four rough categories fall out. Heavy and rigid points to a rigid gripper, possibly with force sensing layered on top. Heavy and soft or deformable points to a hybrid rigid-flexible design, or granular jamming where its conformable grip suits the geometry. Light and rigid usually means vacuum or a rigid jaw, surface permitting. Light and soft or fragile points toward soft pneumatic, silicone elastomer, or electroadhesive film for anything flat, smooth, and delicate.
How object sensitivity and damage risk shape the final choice
Sensitivity works as a tiebreaker, not a first-pass filter. By the time an object has survived the surface test and the payload test, several gripper candidates are usually still standing, and what separates them is how much contact force or deformation each one puts on the object at the moment of grasp. Food, medical devices, consumer electronics packaging, biological samples: all carry damage thresholds tight enough to force a decision even when the earlier tests came back inconclusive.
Soft pneumatic and silicone-elastomer grippers are the default answer for anything fragile, because passive deformation spreads contact force across a wider area instead of concentrating it at a point, which lowers the peak stress the object actually feels. The added safety around people working nearby is a secondary benefit, not the main reason to pick them.
Electroadhesive film grippers earn their place on flat, fragile, smooth surfaces specifically because they trade clamping force for a friction coefficient that can be dialed up or down electrically. That swap cuts damage while still increasing grip, and it lets gripping force stay independent of the object's material properties, which matters a great deal when one line runs several sensitive materials back to back without retooling between them.
Granular jamming's sensitivity profile is decent, not perfect. It conforms without clamping, so peak contact stress stays low; the hardening step, though, applies vacuum unevenly on objects that are very fragile or oddly shaped, and that unevenness is worth testing against the specific geometry before committing to it at scale.
Gecko-inspired adhesion is the answer for the most sensitive, no-contact-force scenarios on the list. Van der Waals forces mean no clamping, no suction-driven deformation, no penetration of any kind, which makes this the right call for glass, polished metal, or thin film material where any contact force at all risks a scratch or a crease. This is also where rigid grippers get ruled out even after clearing every earlier filter: if surface marking, deformation, or fracture counts as a quality failure, sensitivity overrides whatever speed and force advantage the rigid design was offering.
Applying the four-variable framework: worked examples by environment
E-commerce fulfillment is the textbook mixed-SKU bin-picking problem: cardboard boxes that are flat and non-porous but wildly inconsistent in size, polybags that are porous and floppy, blister packs that are rigid, smooth, and easy to scuff. The surface filter alone splits this apart, since hybrid vacuum with real-time high-vacuum and high-flow switching handles the boxes and the polybags, but plain suction fails on the polybags without that high-flow mode engaged. Payload is a non-issue here, light to moderate loads across the board, so both soft and hybrid vacuum designs clear that test easily. Sensitivity is what narrows it down: blister packs rule out clamping outright, so suction or electroadhesive becomes the preferred contact method. The likely verdict is a hybrid vacuum gripper handling the bulk of the volume, with soft pneumatic or electroadhesive kept in reserve for the highest-sensitivity SKUs. Worth flagging separately: robotic systems typically grasp one object per pick, while a human hand manages multiple items with little effort, and that gap is a real efficiency drag in fulfillment work. Novel hardware approaches are among the directions currently being explored to close that gap.
Food processing brings a different mix: irregular fresh produce that's soft and easily bruised, sealed rigid trays that are smooth and non-porous, pouches with a porous seal area but a floppy body. Surface filtering sends produce toward granular jamming or soft pneumatic, trays toward vacuum, and pouches toward either hybrid suction or a soft gripper depending on exactly where the seal sits. Stiffness backs that up: produce sits at the low end where soft or granular jamming clearly wins, while the trays pass cleanly to vacuum. Sensitivity decides produce specifically, since skin damage counts as a quality failure on its own, and granular jamming's distributed contact avoids the concentrated force that jaw clamping applies. The likely setup is a two-gripper configuration, or a single soft gripper fitted with a vacuum attachment for the trays, with contact-force sensing adding supplementary object-characterization value on the side.
Industrial assembly with mixed ferrous and non-ferrous parts is the cleanest case for a single unified system, and arguably the only environment on this list where a broad-capability gripper is a defensible procurement call. Machined steel parts are heavy, rigid, and metallic; aluminum castings are moderate weight and smooth; rubber seals are light, soft, and irregularly shaped. The surface and material filter opens up the electromagnetic option specifically for the steel parts, using surface material detection, while the rubber seals fall to suction or a soft gripper. Payload confirms that split: steel favors a rigid or hybrid rigid-flexible gripper, while the light rubber seals pass easily to soft. Sensitivity barely factors in here, since neither the steel nor the aluminum is fragile in any meaningful sense, and the rubber seals deform without actually being damage-prone. The likely verdict is a hybrid rigid-flexible gripper with an electromagnetic auxiliary function for ferrous detection, covering the full material range from one system with no hardware changeover between parts.
Run all three environments back through the same four questions, surface, stiffness, payload, sensitivity, and a pattern holds across all of them: no single gripper wins every filter, but the order in which the filters get applied is what actually narrows five options down to one defensible choice. Get the order backwards, start with payload instead of surface, say, and the exercise degrades into the same procurement error this piece opened by arguing against.